Autonomous UAVs. Real autopilots. One arena.
Every aircraft runs real ArduPlane autopilot software, commanded over MAVLink exactly as on a real airframe. An automatic referee scores every lock-on, dive and landing, live. Test your autonomy code against real opponents without risking an aircraft.
Fifteen minutes. Four tasks. No mercy from the referee.
Points below are from the standard rules. Every rule lives in one configuration file, so leagues can change the format without touching code.
Take off
Each aircraft takes off inside the take-off window, flown by the team's own code or by a pilot from the 3D cockpit.
Lock on
Hold an opponent inside your camera's hit zone for 4 seconds. Being locked on costs 2 points.
QR dive
Dive at the ground pad and read its QR code from the camera image.
Land
Land safely in the zone before time runs out. Geofence breaches, no-fly zones and unsafe flying cost points.
Every lock-on is checked against ground truth.
Each aircraft's forward camera is rendered as real images and streamed only to its own team. When a team claims a lock-on, the referee replays the camera projection, the hit zone and the hold time, and keeps a short evidence clip like this one.
- Camera projection, hit zone, hold time and gaps verified
- Live penalties for geofence, no-fly zones, unsafe proximity and false claims
- Every telemetry message, claim and decision logged for replay
See a match from every seat.
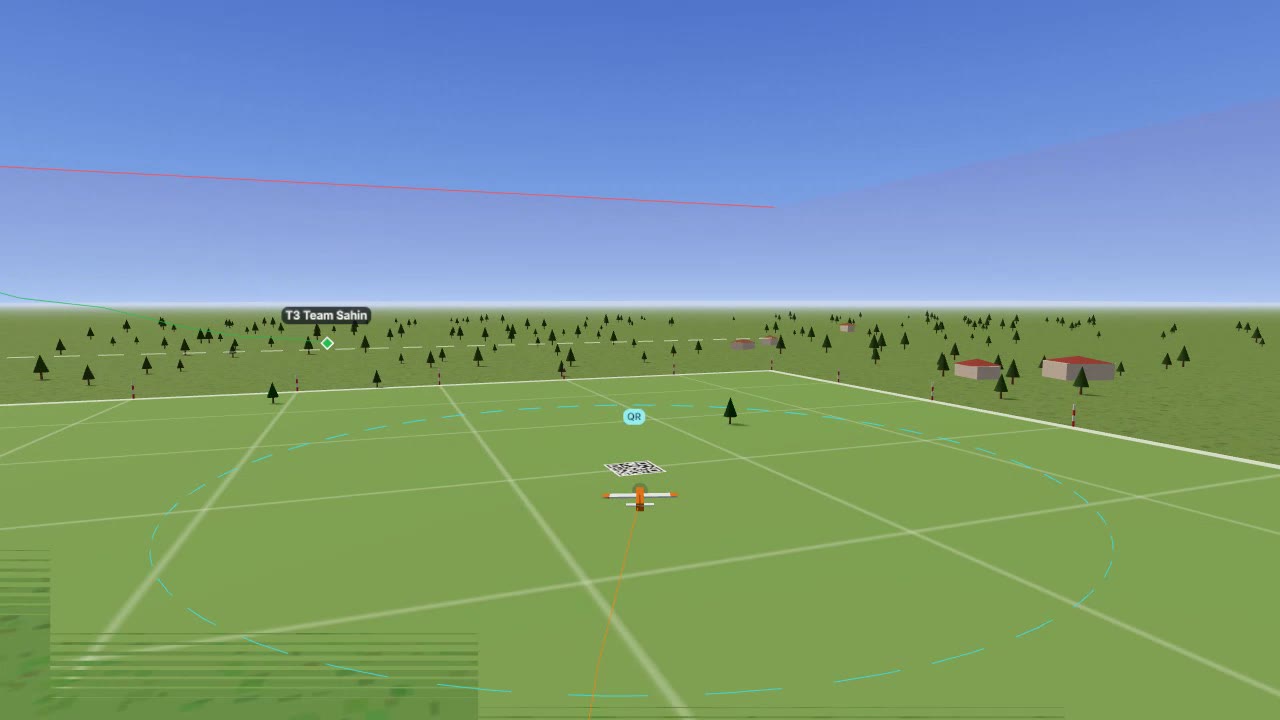
All images on this page come from real UAV Arena matches. Nothing is staged or rendered for marketing.
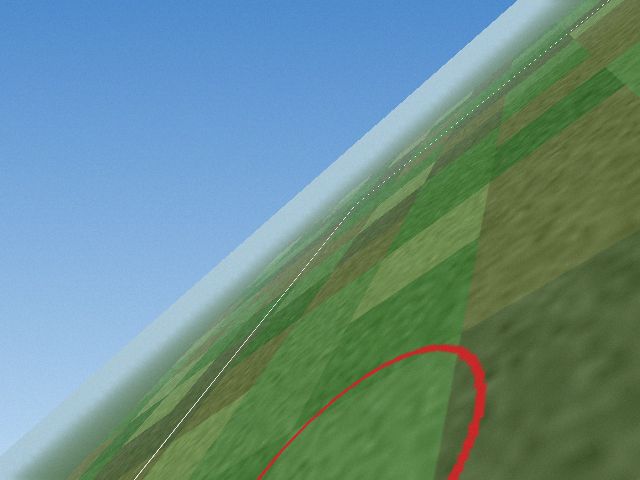 ONBOARD CAMERA
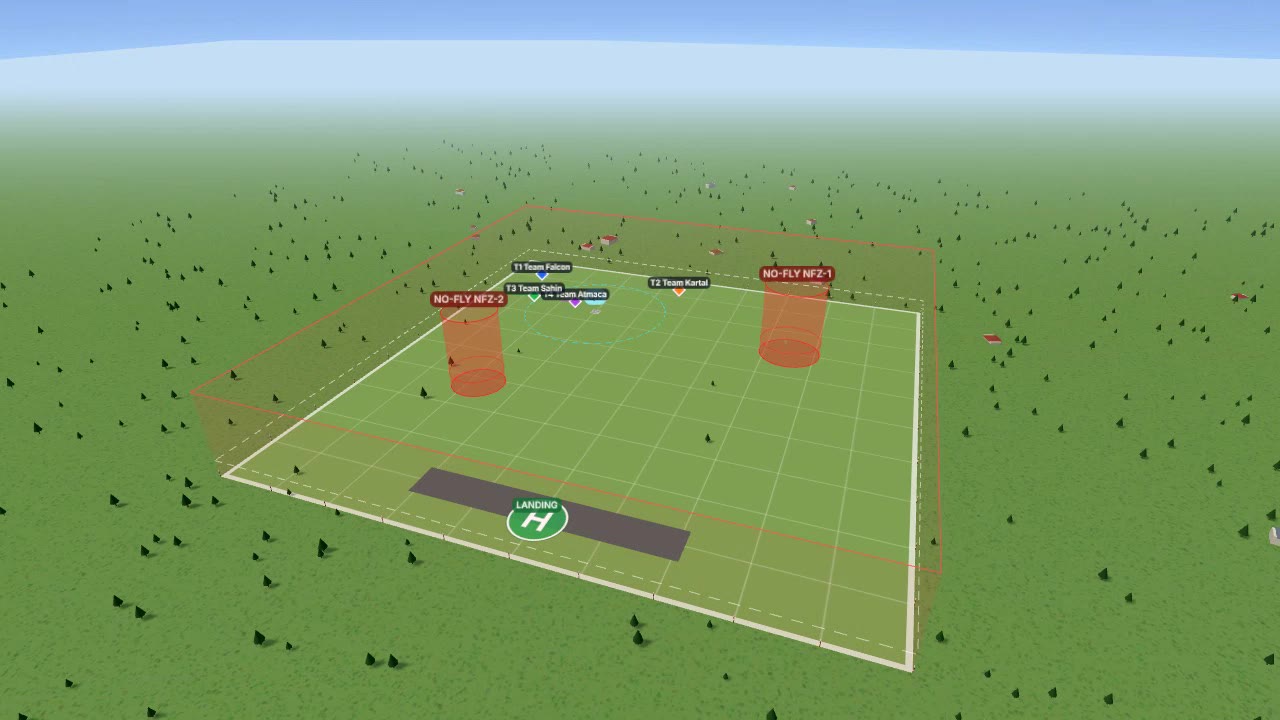 ARENA OVERVIEW
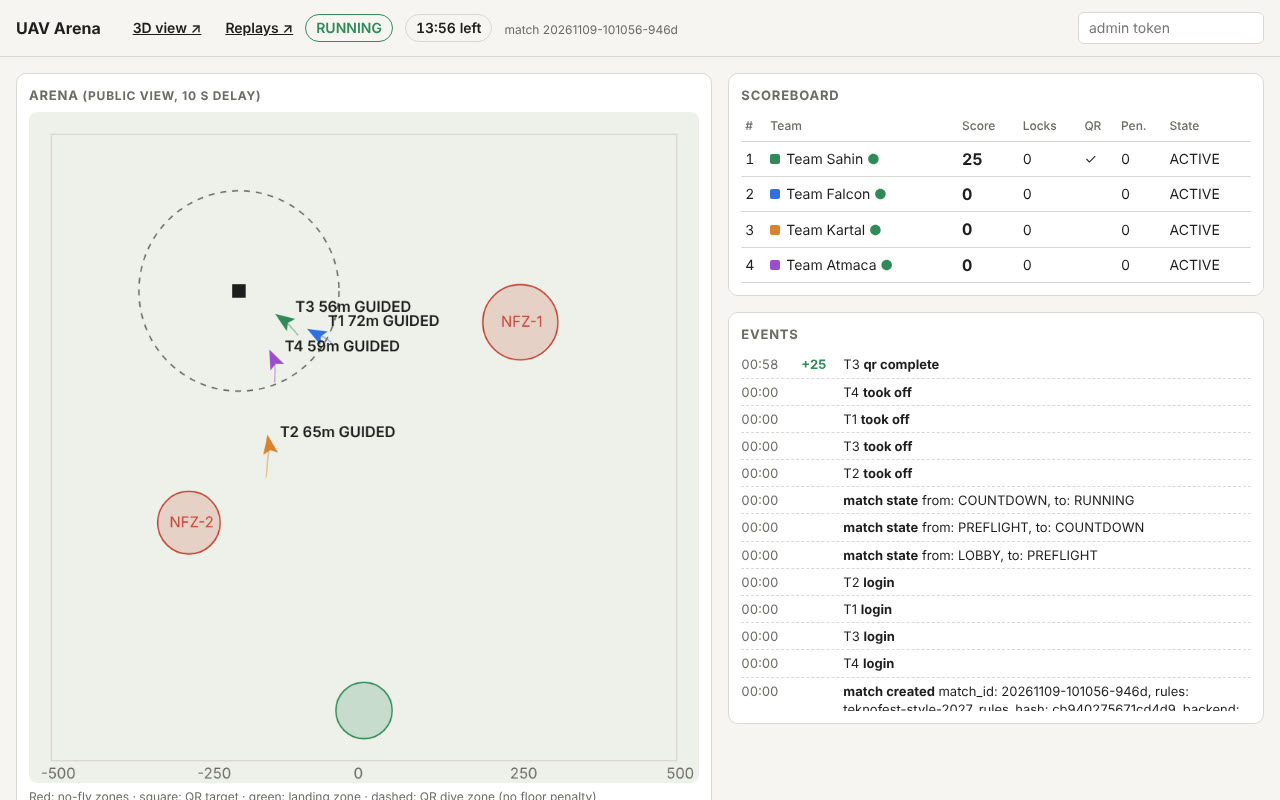 REFEREE DASHBOARD
The same software that flies the real aircraft.
Real autopilots
ArduPilot SITL for every aircraft, PX4 alongside it, commanded over MAVLink.
Rendered cameras
Real images per aircraft, streamed as MJPEG to each team for its own detector.
Replays
Every match replayed in 3D with a timeline, events and 1–32× speed.
Fair play
Per-team tokens and an autopilot gateway that blocks forbidden commands and logs everything.
3D cockpit
Fly by hand from the browser with keyboard or gamepad, or with Mission Planner.
Built to scale
100 teams in one match with every team's full 5 Hz telemetry, measured.
Beyond the competition format.
Optional modules for leagues that want electronic warfare in the air. Each one switches on or off per season.
Ground radar
Noise, clutter, radar horizon and a tracker; tracks offered to teams.
Hidden SAM sites
Track, lock, launch. Teams get a radar warning receiver to survive.
GPS jamming and spoofing
Zones where the position lies; detecting it is the team's job.
Comms jamming
Latency, loss and jitter per team, and jamming zones on the link.
Self-protection jammer
An ECM with a budget and cooldown, to spend wisely.
Fog of war
No free positions of opponents: find them with radar and camera.
From student teams to defense engineers.
Competition teams
Practise against real opponents months before a flight test. Built around the Fighting UAV competition format.
Universities and leagues
Run courses, internal team selection or a full league on one platform, with automatic scoring and replays.
Companies
Test multi-aircraft autonomy software against standard scenarios before risking an airframe.
What test matches taught us.
Deconfliction before tactics.Two aircraft running identical code collided 24 seconds after take-off.
Aim past the target.A guided dive failed on every pass until the aim point moved beyond the QR pad; then every team read the code on its first dive.
Stagger the landings.Two aircraft returning at the same moment met on final approach.
Test the swarm before you fly it.
Testing several autonomous aircraft together on real hardware is slow, expensive and risky. UAV Arena runs the same autopilot software in a shared virtual airspace, with automatic scoring and full logs of every flight.
- Test your autonomy codeagainst standard multi-aircraft scenarios before a flight test
- Run a hiring challengefor interns and graduates, under your own brand
- Train new engineerson MAVLink, ArduPilot and multi-aircraft operations without hardware
- Run it on your own networkwith your aircraft models and closed scenarios (in development)
Join the first league.
A free virtual practice league for university UAV teams. Use your own autonomy code, or start from the provided starter team. Registration takes two minutes with a GitHub account.
UAV Arena is an independent project inspired by the Fighting UAV (Savaşan İHA) competition format. It is not affiliated with or endorsed by TEKNOFEST or its organizers.